ME 2016 Exam 2
 Call Kai
 Learn
 Practice Test
 Spaced Repetition
 Match
 Flashcards
 Knowt Play
1/74

There's no tags or description
Looks like no tags are added yet.
75 Terms
Polynomial Interpolation
determining the nth order polynomial that fits n+1 data points
general form of nth order polynomial
fn(x) = a0 + a1x +a2x²
How many nth order polynomials fit n+1 data points
one but there are a number of mathematical formats in which the polynomial can be expressed
Newton Divided Difference
fn(x) = b0 + b1(x-xo) + b2(x-xo)(x-x1) ….
Newton Divided Difference zeroth coefficient
b0 = f(x0)
Newton Divided Difference 1st coefficient
b1 = f(x1) - f(x0) / (x1-x0)
Newton Divided Difference 2nd coefficient
b2 = ( (f(x2) - f(x1) /(x2-x1)) - b1) / (x2-x0)
When to use Newton interpolating polynomial
when the order of the polynomial is unknown
Use to use Lagrange interpolating polynomial
the order of the polynomial is known
spline interpolation
determining n low order piecewise polynomials through n+1 data points
Why use splines over polynomial interpolation
polynomial interpolation can lead to wild oscillations for high order polynomials or when function of interest has local, abrupt changes
how many knots in spline interpolation
n+1
how many intervals in spline interpolation
n
linear spline formula without solved coefficients
Si(x) = ai + bi(x-xi)
quadratic spline formula without solved coefficients
Si(x) = ai + bi(x-xi) + ci(x-xi)²
linear spline coefficients
ai = fi , bi = (fi+1 - fi)/ (xi+1 - xi)
Disadvantages of linear spline
non-smooth, discontinuous, 1st derivative
Quadratic and Cubic splines impose
higher order smoothness conditions, in addition to the continuity conditions of linear
How many conditions for linear splines
2n
How many conditions for quadratic splines
3n
How many conditions for cubic splines
4n
Spline conditions on function values consist of
function values of adjacent polynomials must be equal at interior knots and first and last polynomials must pass through exterior knots (2n conditions)
function values of adjacent polynomials must be equal at interior knots number of conditions
2(n-1)
first and last polynomials must pass through exterior knots number of conditions
2 conditions
function values of adjacent polynomials must be equal at interior knots condition formulas
Si-1(xi) = f(xi) and Si(xi) = f(xi)
first and last polynomials must pass through exterior knots formulas
So(xo) = f(xo) and Sn-1(xn) = f(xn)
Spline conditions at first derivative at interior knots number of conditions
n-1
Spline conditions at first derivative at interior knots formula
S’i-1(xi) = S’i(x)
Spline conditions at second derivative at interior knots number of conditions
n-1
Spline conditions at second derivative at interior knots formula
S’’i-1(xi) = S’’i(xi)
After first derivative conditions how many more conditions needed for quadratic spline
1
After second derivative conditions how many more conditions needed for cubic spline
2
Natural end conditions
S0’’(xo) = S’’n-1(xn) = 0
Clamped end conditions
S’o(xo) = f’(xo) , S’n-1(xn) = f’(xn)
not-a-knot end conditions
S’’’o(x1) = S’’’1(x1) , S’’’n-2 (xn-1) = S’’’n-1(xn-1)
Newton-Cotes integration formulas
replace a complicated function or tabulate values with an approximating function that is easy to integrate
Newton-Cotes Trapezoid Rule integration formula
(b-a) * f(a)+f(b)/2
Trapezoid Rule error indicates
it is exact for linear function
Multi-application trapezoid rule
divide integration interval into number of segments, apply trapezoid rule to each segment, and then sum them
Multi-application trapezoid rule formula

Multi-application trapezoid rule error
as number of segments doubles error reduced by 1/4

For multi application trapezoid error at some point as the number of segments increase
roundoff error may intrude
Using trapezoid rule is good for
individual applications of nicely behaved functions
For high accuracy multi-application trapezoid rule
can be expensive
Simpsons 1/3 rule requires
an additional point midway between a and b
Simpsons 1/3 rule uses what type of polynomial
2nd-order
Simpsons 1/3 formula
(b-a) * (f(x0) + 4f(x1) + f(x2))/6

Simpsons 1/3 error indicates it is
exact for any cubic polynomial
Multi-application Simpsons 1/3 requires
an even number of segments
Multi-application Simpsons 1/3 formula

Multi-application Simpsons 1/3 error
as number of segments is doubled error reduced by 1/16

Romberg Integration
combine multiple low order estimates to achieve a higher order estimate of the integral
Adaptive Quadrature
Able to generate more efficient estimate with adaptive stepsize
Gauss Quadrature
An improved estimate can come from strategically choosing evaluation point away from end points
n point Gauss-Legendre formula takes the form
I = c0*f(xo) + c1*f(x1) + …+ cn-1*f(n-1)

differential equation
an equation composed of an unknown function and its derivative
An ODE is a differential equation with
one independent variable
In an IVP all
auxiliary conditions are specified at the same value as the independent variable
Eulers method
approximate slope in the interval as the slope of xi
Eulers formula
yi+1 = yi + f(xi,yi)h

Order of Euler’s method global truncation error
O(h), as we halve stepsize error reduces by half
Heun’s method
approximate slope as average over interval
Heun’s method formula
yi+1 = yi + (f(xi,yi) + f(xi+1, y0i+1) )/2 * h

Eulers method reminiscent of
forward finite difference
Heuns method reminiscent of
center finite difference
Heun’s method error is of order
O(h²), as we halve stepsize we quater error
Midpoint method
uses an approximate slope at midpoint of interval
Midpoint method formula
yi+1 = yi + f(xi+1/2, y0 i+1/2) *h
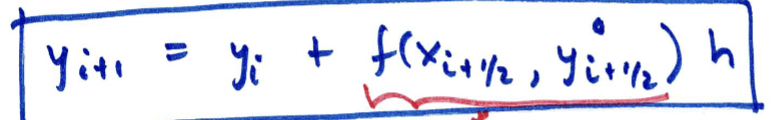
Midpoint method reminiscent of
centered finite difference
Midpoint method order of error
O(h²), as we halve the stepsize we quarter the error
Runge-Kutta method uses an
increment function to represent slope over interval
Increment function form
a1k1 + a2k2 … ankn
When using Runge-Kutta method for low order methods
n dictates the order of the method
3rd order RK error
O(h³), when stepsize half error reduces by 1/9
4th order RK error
O(h^4), when stepsize half error reduces by 1/16