MATH 54
 Call Kai
 Learn
 Practice Test
 Spaced Repetition
 Match
 Flashcards
 Knowt Play
1/65

Earn XP
Description and Tags
True / False
Name | Mastery | Learn | Test | Matching | Spaced | Call with Kai | Chat |
|---|
No analytics yet
Send a link to your students to track their progress
66 Terms

true: each of the three elementary row operations can be undone by performing another of the same type

true: row equivalent linear systems have the same solution set

false: rows x columns
false: two matrices are row equivalent if one can be transformed into the other by using elementary row operations

false: (s1, … , sn) is one solution; a solution set is in {} and has all solutions of the system

false: a consistent system has at least one solution; an inconsistem system has no solutions

true: does a solution exist at all? if so, is it the only one?

true: two systems are equivalent iff they share the same solution set

false: each matrix can only be reduced into one unique reduced row echelon matrix

false: the reduced row echelon form of a matrix is unique, but a matrix can be reduced into many different echelon forms
false: pivot positions remain the same regardless of row operations; the reduced row echelon form is unique
true: basic variables correspond to pivot columns; free variables correspond to nonpivot columns
true: forward phase transforms the matrix into row echelon form; backward phase transforms the matrix into reduced row echelon form

false: fr`ee variables can take any value, so a system with free variables has no or infinitely many solutions

true: nothing cannot equal something
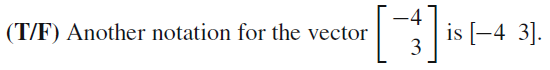
false: column vector is not equivalent to row vector

true: by definition, R5 is the collection of all ordered sequences of five real numbers

false: two points in a plane lie on the same straight line passing through the origin only if they are scalar multiples of each other
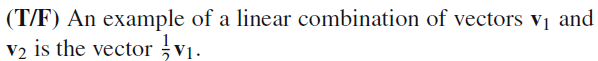
true: c1 = 1/2, c2 = 0
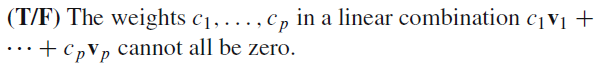
false: linear combination allows the scalars to be any real numbers with no restriction;

true: c2 = 0

false: if u and v are scalar multiples, Span{u, v} is a line through the origin; if u and v are both the zero vector, their span contains only the zero vector, which is a single point at the origin
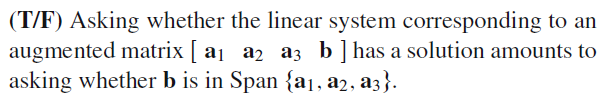
true: b being in Span{a1, a2, a3} means b can be written as a combination of those three vectors

false: Ax=b is a matrix equation

true: Ax = a1x1 + a2x2 + … + anxn = b
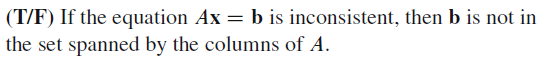
true: Ax=b is inconsistent if it cannot be expressed as the linear combination of the columns of A
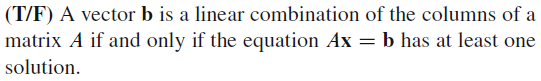
true: Ax=b is consistent if it can be expressed as the linear combination of the columns of A

false: a system of linear equations is consistent iff the righmost column of the augmented matrix is not a pivot column

true: if the columns of a matrix A span Rm, every vector b in Rm can be written as a linear combination of those columns, which is equivalent to saying that Ax=b is consistent for every b in Rm; so if the columns of A do not span Rm, there must be at least one b for which Ax=b is inconsistent

true: if the columns of a matrix A span Rm, every vector b in Rm can be written as a linear combination of those columns, which is equivalent to saying that Ax=b is consistent for every b in Rm

true: Ax = b is the same as [a1 a2 … a]

true: for each b in Rm, the equation Ax=b has a solution = the columns of A span Rm = A has a pivot position in every row

true: a homogeneous equation Ax=0 always has the trivial solution x=0

false: x only has to have at least one nonzero entry

false: implicit because it only states a condition/rule that x must satisfy to be included in the set

true: valid plane because it’s made up ot two linearly independent vectors, and passes through the origin when x2=x3=0

false: the homogeneous equation always has the trivial solution


true: an equation is homogeneous if b=0, true when x is the zero vector

false: a line through p parallel to v

true: adding a fixed vector p to any vector v acts like a translation

false: misses the condition that Ax=b must be consistent; if it has a solution the answer is true, if false the set is empty

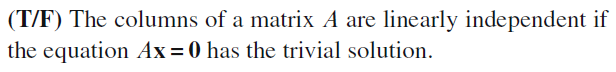
false: linearly independent if Ax=0 only has the trivial solution; Ax=0 always has at least the trivial solution

true: two vectors are linearly dependent if they are scalar multiples of each other

false: S is linearly dependent if at least one of its vectors is a linear combination of the others

false: a set containing more vectors that there are entries (n>m in Rm) is automatically linearly dependent, but the reverse is not a guarantee

true: if n>m, the set is automatically linearly dependent

true: z being in Span{x, y} means it can be written as a linear combination of x and y, so {x, y, z} is automatically linearly dependent

true: z must be a linear combination of x and y in this case

false: if a set contains more vectors than there are entries in each vector then the set is linearly dependent, but the set being linearly dependent does not guarantee that there are more vectors than entries

true: every matrix transformation automatically satisfies the properties of vector addition and scalar multiplication
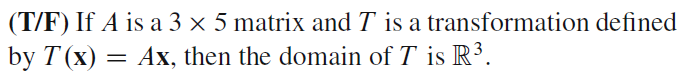
false: domain is n, codomain is m

false: the statement describes the range of the transformation; the codomain is the entire target space Rm where the outputs land, regardless of whether ever vector in that space can actually be reached

false: for an mxn A, the space Rm is the codomain (target space) but not necessarily the range (actual set of outputs)

false: the given question is the existence question
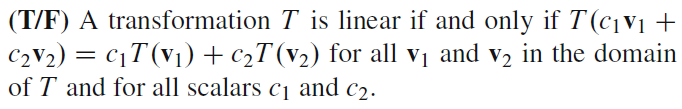
true: combines the properties of vector addition and scalar multiplication

true: translates to T(c1v1 + c2v2) = c1T(v1) + c2T(v2)

true: any vector x in Rn can be written uniquely as the linear combination of the standard basis vector e1, e2, …, en, which are columns of In

false: a mapping is one-to-one (injective) if each vector b in Rm is the image of at most one x in Rn
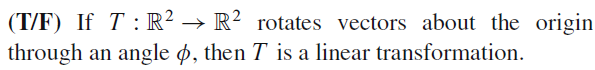
true: rotations are linear transformations
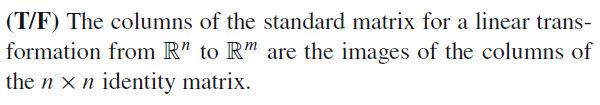
true: if T: Rn → Rm is a linear transformation, its standard matrix A is uniquely constructed using the images of the standard basis vectors, which are the columns of In

false: the composition of two linear transformations is always a linear transformation

false: any linear transformation with domain Rn and codomain Rm is a matrix transformation

false: a mapping is onto (surjective) if every vector b in Rm is the image of at least one vector x in Rn

true: the given matrix can represent transformations where the x1 and x2 are modified independent of each other; the matrix could not represent rotations, reflections across slanted lines, shears, or non-linear transformations (translations)
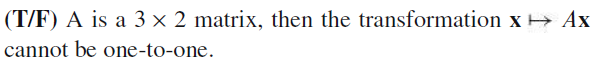
false: possible for A to have a pivot in every column

true: impossible for A to have a pivot in every row