Comprehensive Guide to Parametric, Vector, and Polar Calculus
Parametric Equations and Curves
Basics of Parametric Equations
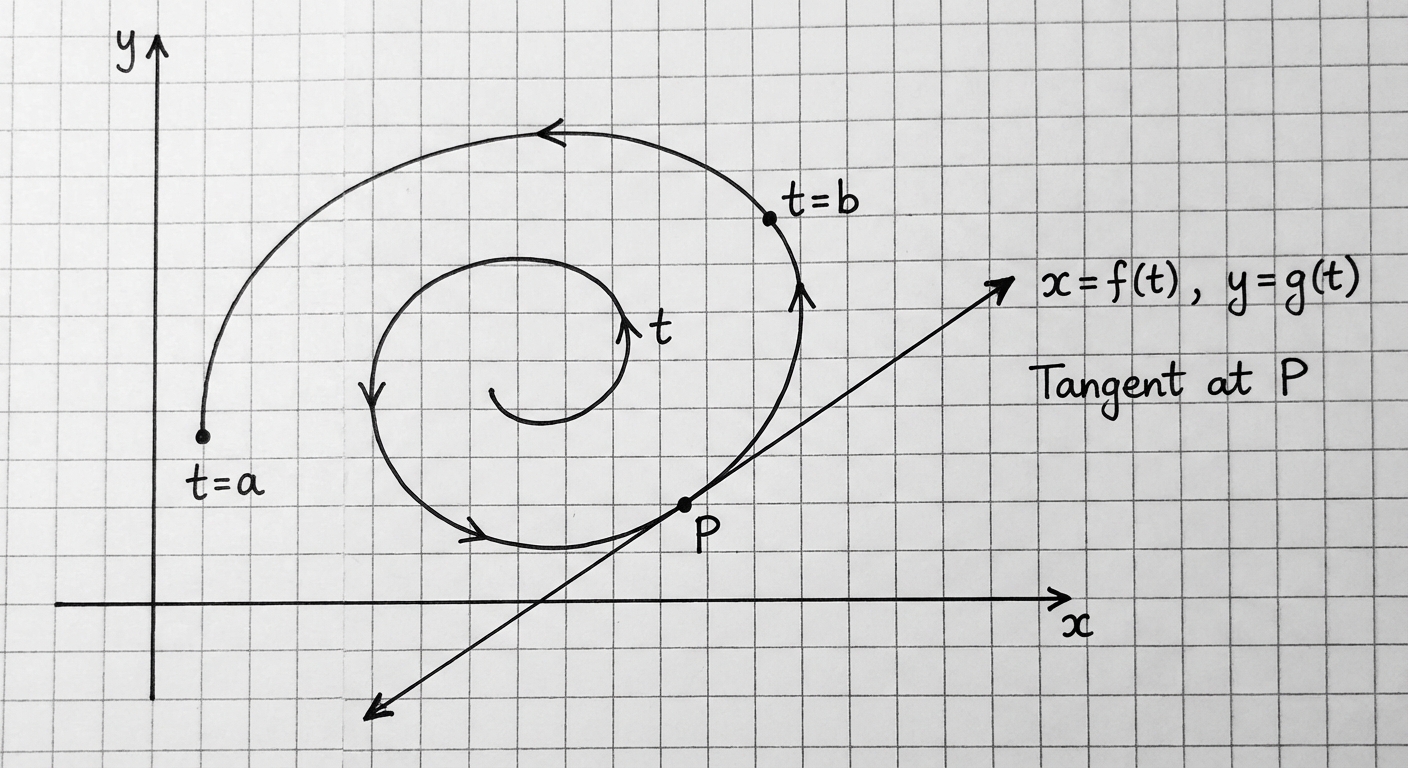
In standard Cartesian coordinates, we define graphs as , describing a static relationship between horizontal and vertical position. However, in Parametric Equations, we introduce a third variable, called a parameter (usually represented as for time), to define both and independently.
A plane curve is defined by a pair of functions:
Here, and are dependent variables, and is the independent variable. As varies over an interval , the point traces a curve in the plane. Unlike a static graph, a parametric curve has an orientation or direction of motion.
Differentiation in Parametrics
To analyze the slope of a parametric curve at a specific point, we need to find . We apply the Chain Rule:
Tangent Lines
- Horizontal Tangents: Occur where and .
- Vertical Tangents: Occur where and .
The Second Derivative
A frequent potential pitfall on the AP exam is the second derivative. It is not typically . Instead, it represents the rate of change of the slope with respect to :
Process:
- Find the first derivative .
- Differentiate that result with respect to .
- Divide by again.
Arc Length of Parametric Curves
To find the distance a particle travels along a curve from to , we integrate the speed. Because and change independently, we use the Pythagorean theorem on their rates of change:
Vector-Valued Functions
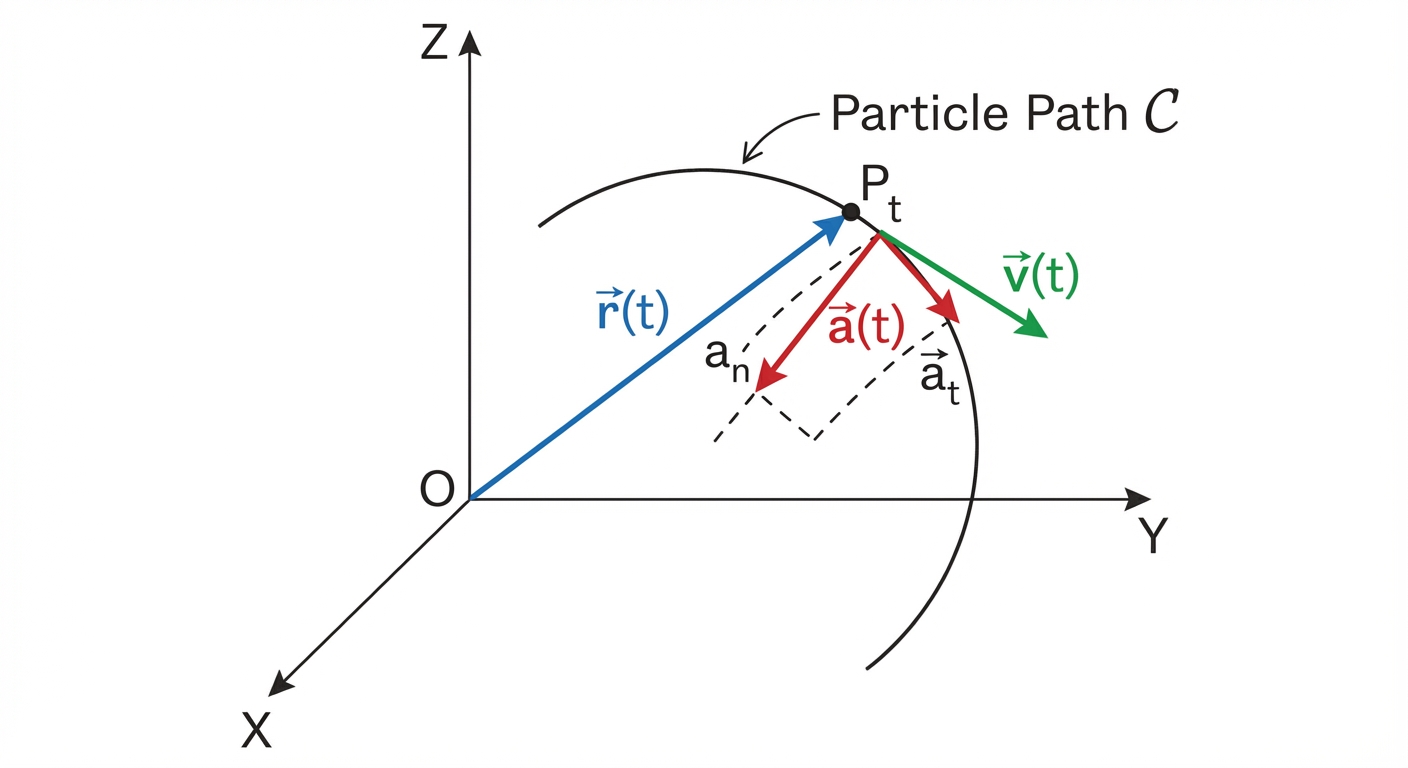
Vector-valued functions are essentially parametric equations written in vector notation. They bridge the gap between calculus and physics, accurately modeling position, velocity, and acceleration.
Definitions and Derivatives
A vector-valued function is often written as:
Differentiation and integration are performed component-wise:
- Position:
- Velocity:
- Acceleration:
Motion Descriptors
In particle motion problems, you must distinguish between these key terms:
Speed: The magnitude of the velocity vector (a scalar).
Displacement: The net change in position (a vector).
Total Distance Traveled: The integral of speed (a scalar). This matches the arc length formula.
Common Mistakes regarding Vectors:
- Confusing speed (scalar) with velocity (vector).
- Forgetting that is always tangent to the path of motion.
- Integrating velocity gets you displacement, not total distance (unless the particle never changes direction).
Polar Coordinates
The Polar Coordinate System
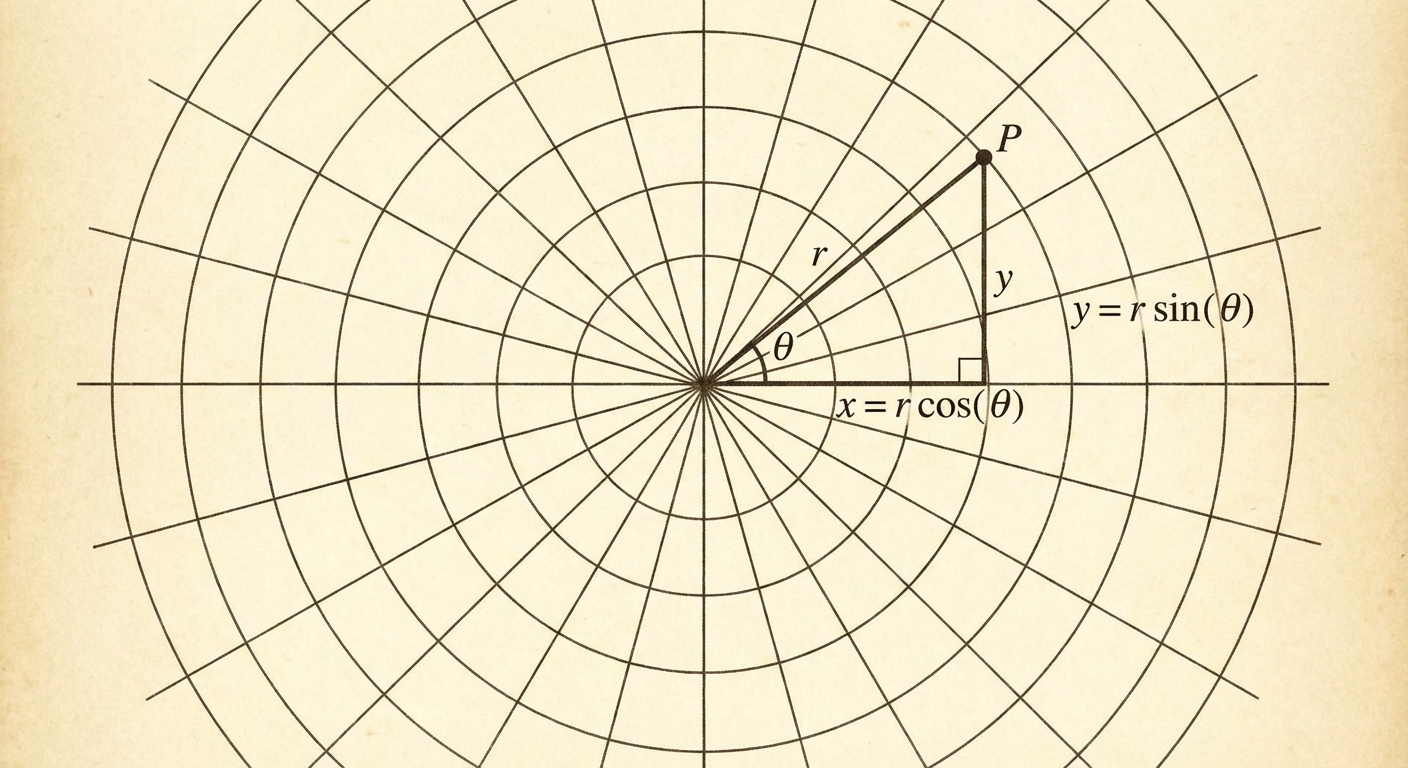
Instead of horizontal and vertical distances , polar coordinates use a distance from the origin (radius ) and an angle from the positive x-axis ().
Conversions
Converting between Cartesian and Polar is based on right-triangle trigonometry:
Polar to Cartesian:
Cartesian to Polar:
Derivatives and Slopes in Polar
To find the slope of the tangent line for a polar curve , we treat it as a parametric set where is the parameter.
Since and , we substitute for using the Product Rule:
Note: represents .
Area in Polar Coordinates
The area bounded by a polar curve is derived from the area of a circular sector (). Since changes as changes, we integrate:
Area Between Two Curves
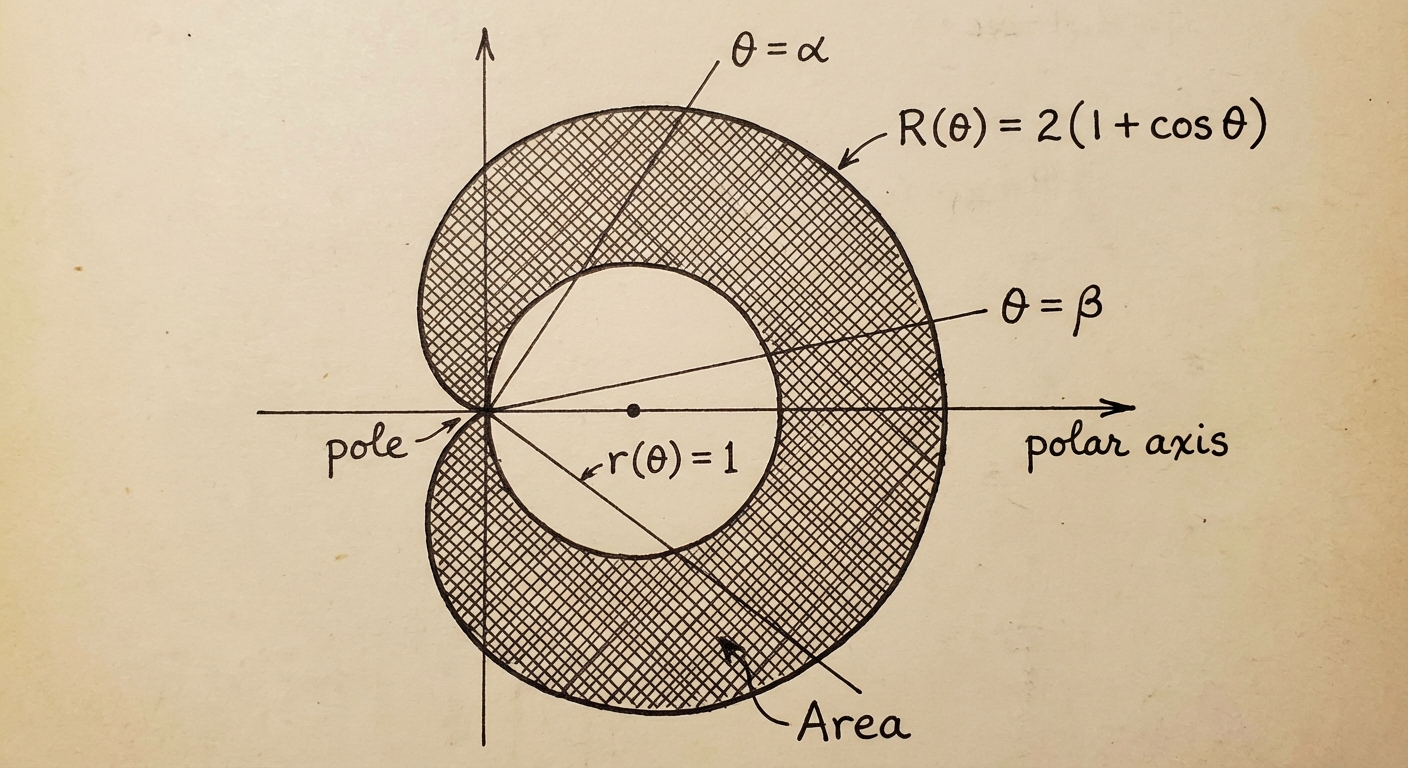
To find the area between an "outer" curve and an "inner" curve :
Crucial Note: We subtract the squares of the radii (). We do NOT calculate . This is a difference of areas, not a square of the difference.
Arc Length of Polar Curves
Although less common than parametric arc length, it is part of the BC curriculum. It is derived from the parametric formula:
Section Summary: Common Pitfalls
- The Second Parametric Derivative: Students often calculate . Remember, you must differentiate with respect to and then divide by .
- Polar Area Constant: Forgetting the in front of the integral is the most common error in Unit 9.
- Polar Difference of Squares: When finding the area between polar curves, write , never .
- Vector Magnitude: Speed is the magnitude of velocity. It must be positive (it involves a square root). Velocity is a vector (indicated by angle brackets ). don't confuse the two.